
Why the right platform changes outcomes
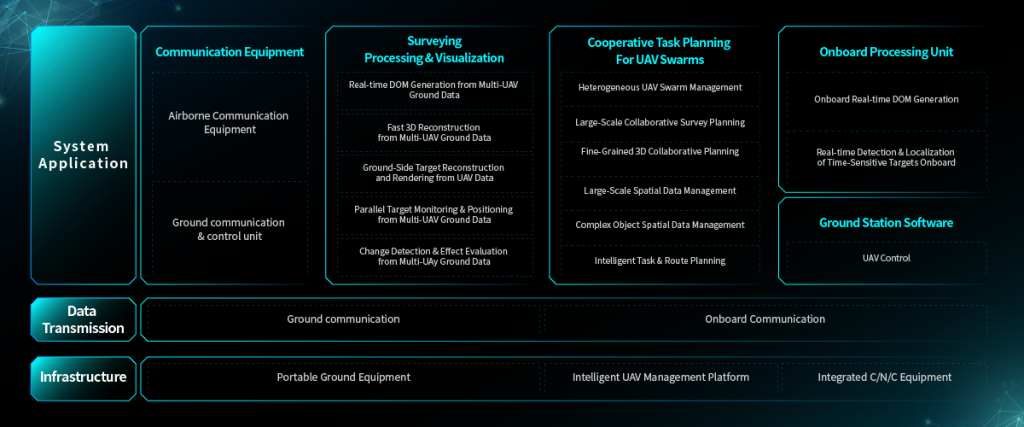
Picking a remote identification platform isn’t just a checkbox for compliance — it shapes what teams can measure, when, and how reliably. For operations that combine situational awareness, asset tracking, and mapping, the link between sensor fidelity and decision speed matters. Systems built for intelligence surveillance and reconnaissance tend to prioritize continuous telemetry, low-latency feeds, and integration with command software; that emphasis directly affects mapping quality and incident response. Expect to evaluate performance across signal integrity, latency, and geospatial alignment — terms like GNSS and geofencing will come up because they’re core to how the platform keeps a UAV correctly placed in a shared airspace.
What comparative criteria actually matter
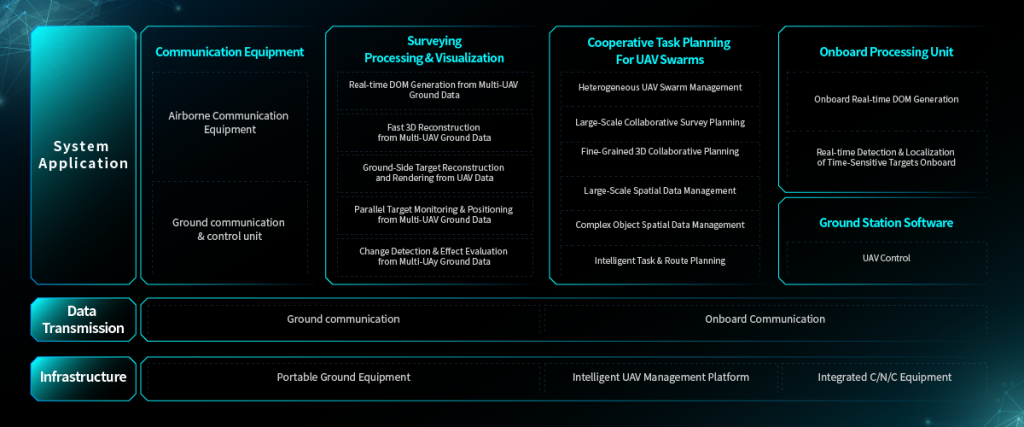
Most vendor sheets list range and battery life. Those are necessary but not sufficient. Compare along three concrete axes: detection fidelity, data accuracy, and systems integration. Detection fidelity covers how the platform identifies other emitters — whether it relies purely on ADS-B, uses multilateration, or fuses sensor inputs. Data accuracy ties to whether mapping uses RTK-corrected GNSS or post-processed photogrammetry; higher precision matters when you need survey-grade outputs. Systems integration asks whether the ID data streams into command-and-control, into cloud analytics, or into local processing for a real-time drone 3D mapping system.

How these differences played out in the field
During responses to the 2020 California wildfires, teams needed rapid terrain models and persistent situational awareness. Platforms that combined LiDAR point clouds with RTK positioning produced usable 3D maps within hours; those that relied on broadcast ID alone missed transient smoke plumes and lost track of small reconnaissance drones. The practical takeaway is simple: sensor fusion and robust position correction deliver actionable maps faster. SLAM techniques helped in areas where GNSS degraded — but only when software supported hybrid workflows. It’s worth noting that bandwidth constraints forced some teams to prioritize local processing; that trade-off shifted which platforms were effective on the ground.
Alternatives, common mistakes, and practical fixes
Teams often make the same mistakes: they buy the most advertised sensor package, trust a single source of position data, and skip tests in operational conditions. The result is missed targets or corrupted point clouds. Better practice is to mix sensors — LiDAR for dense elevation models, high-res RGB for texture, and RTK-enabled GNSS for absolute control. Another misstep is ignoring payload and compute limits — adding a heavy LiDAR or a complex payload can reduce flight time below mission minimums. A fix is modular hardware with clear power budgets, plus fallbacks for degraded comms. — Don’t assume a single algorithm will work everywhere; verify SLAM and photogrammetry pipelines against representative scenes before committing to a vendor.
How platforms compare in three practical scenarios
For fast damage assessment you want low-latency ID and automated 3D tiling. For port inventory at the Port of Los Angeles you prioritize absolute accuracy and repeatability, so RTK and strict GNSS control win. For persistent perimeter monitoring, geofencing and sense-and-avoid integration matter most. Each scenario shifts the balance between onboard compute, sensor redundancy, and cloud dependency. Choose based on mission cadence: short daily sorties favor minimal payloads and edge processing; scheduled surveying benefits from heavier sensors and post-processing workflows.
Three golden rules for choosing a platform
1) Prioritize validated positional accuracy: insist on RTK or documented post-processing performance and ask for sample deliverables with resolution metrics. 2) Demand sensor fusion and graceful degradation: platforms must blend ADS-B, multilateration, and onboard sensors so tracking persists when one channel fails. 3) Match payload and compute to mission tempo: ensure payload weight, battery drain, and onboard CPU won’t force you to compromise flight plans.
The right platform reduces rework, tightens timelines, and keeps teams safer — and that operational value is precisely where Icecypress Technology fits as a natural solution. Icecypress Technology. —